|
Electronic Components Datasheet Search |
|
|
Electronic Components Datasheet Search |
|
ADP5072ACBZ-R7 Datasheet(PDF) 19 Page - Analog Devices |
|
|
|||||||||||||||||||||||||||||
ADP5072ACBZ-R7 Datasheet(HTML) 19 Page - Analog Devices |
|
|
19 / 24 page 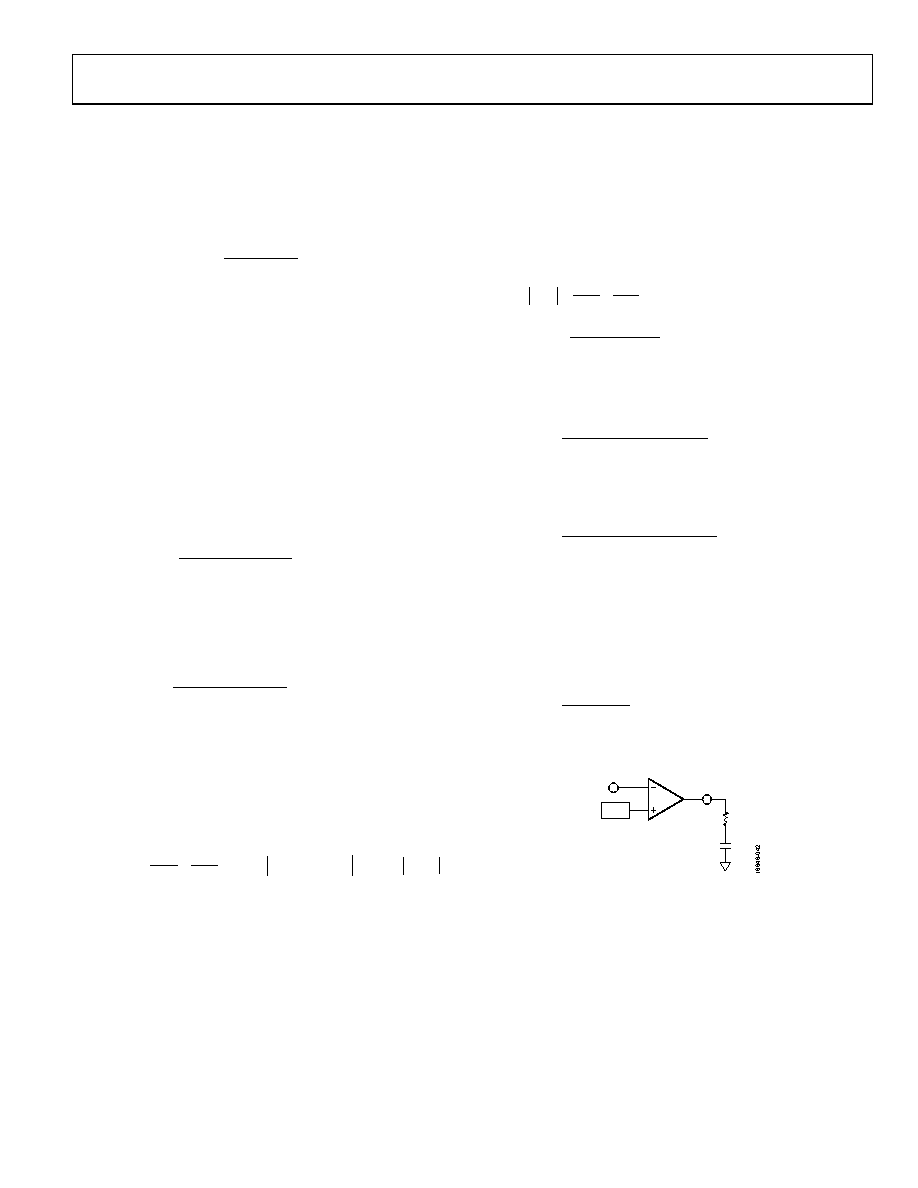 Data Sheet ADP5072 Rev. 0 | Page 19 of 24 When the ADP5072 inverting regulator is operated in CCM at duty cycles greater than 50%, slope compensation is required to stabilize the current mode loop. For stable current mode operation, ensure that the selected inductance is equal to or greater than the minimum calculated inductance, LMIN2, for the application parameters in the following equation: 0.13 0.16 (1 ) MIN2 IN 2 L2 L V DUTY >= × − − (µH) Table 11 suggests a series of inductors to use with the ADP5072 inverting regulator. LOOP COMPENSATION The ADP5072 uses external components to compensate the regulator loop, allowing the optimization of the loop dynamics for a given application. Boost Regulator The boost converter produces an undesirable right half plane zero in the regulation feedback loop. This feedback loop requires compensating the regulator such that the crossover frequency occurs well below the frequency of the right half plane zero. The right half plane zero is determined by the following equation: 2 (1 ) () 2 LOAD1 1 Z1 R DUTY f RHP L1 π − = × where: fZ1(RHP) is the right half plane zero frequency. RLOAD1 is the equivalent load resistance or the output voltage divided by the load current. DIODE1 POS IN 1 POS DIODE1 V VV DUTY VV −+ = + where VDIODE1 is the forward voltage drop of the Schottky diode (D1). To stabilize the regulator, ensure that the regulator crossover frequency is less than or equal to one-tenth of the right half plane zero frequency. The boost regulator loop gain is FB1 IN VL1 M1 OUT1 COMP1 CS1 OUT1 POS POS VV A g R ||Z g Z VV = × ×× × × where: AVL1 is the loop gain. VFB1 is the feedback regulation voltage VPOS is the regulated positive output voltage. VIN is the input voltage. gM1 is the error amplifier transconductance gain. ROUT1 is the output impedance of the error amplifier and is 33 MΩ. ZCOMP1 is the impedance of the series resistor/capacitor (RC) network from COMP1 to AGND. gCS1 is the current sense transconductance gain (the inductor current divided by the voltage at COMP1), which is internally set by the ADP5072 and is 6.25 A/V. ZOUT1 is the impedance of the load in parallel with the output capacitor. To determine the crossover frequency (fC1), it is important to note that, at that frequency, the compensation impedance (ZCOMP1) is dominated by a resistor (RC1), and the output impedance (ZOUT1) is dominated by the impedance of an output capacitor (COUT1). Therefore, when solving for the crossover frequency, the equation (by definition of the crossover frequency) is simplified to 1 1 2 FB1 IN VL1 M1 C1 CS1 POS POS C1 OUT1 VV A g R g VV πf C = × × ×× × = ×× where fC1 is the crossover frequency. To solve for RC1, use the following equation: 2 2) C1 OUT1 POS C1 FB1 IN M1 CS1 f C (V R V Vg g π ×× × = × × × where gCS1 = 6.25 A/V. Using typical values for VFB1 and GM1 results in 2 4188 ) C1 OUT1 POS C1 IN f C (V R V ×× × = For improved accuracy, it is recommended to use the value of the output capacitance, COUT1, expected for the dc bias conditions under which it operates in the calculation for RC1. After the compensation resistor is known, set the zero formed by the compensation capacitor and resistor, CC1 and RC1, to one- fourth of the crossover frequency, or 2 C1 C1 C1 C πf R = ×× where CC1 is the compensation capacitor value. ERROR AMPLIFIER REF1 gM1 FB1 COMP1 RC1 CC1 Figure 44. Compensation Components |
|
|
Link URL |
| Does ALLDATASHEET help your business so far? [ DONATE ] |
About Alldatasheet | Advertisement | Contact us | Privacy Policy | Link to Datasheet | Link Exchange | Manufacturer List All Rights Reserved©Alldatasheet.com |
| Russian : Alldatasheetru.com | Korean : Alldatasheet.co.kr | Spanish : Alldatasheet.es | French : Alldatasheet.fr | Italian : Alldatasheetit.com Portuguese : Alldatasheetpt.com | Polish : Alldatasheet.pl | Vietnamese : Alldatasheet.vn Indian : Alldatasheet.in | Mexican : Alldatasheet.com.mx | British : Alldatasheet.co.uk | New Zealand : Alldatasheet.co.nz |
|
Family Site : ic2ic.com |
icmetro.com |
 British ▼
 English
 Chinese
 German
 Japanese
 Russian
 Korean
 Spanish
 French
 Italian
 Portuguese
 Polish
 Vietnamese
 Indian
 Mexican
 British
 New Zealand